ROS2
Download and installation
The ROS2 driver is an open source wrapper around the C++ Driver, implemented as a single ROS2 package named bota_driver.
Found the package implementation in our official GitLab repository.
bota_driver
on GitLab
XACROs
The bota-driver package provides XACRO macros to simplify the integration of Bota FT sensors into URDFs.
For each sensor type, a dedicated XACRO macro is provided to simplify the creation of the sensor’s URDF description. These macros automatically generate the required links and joints, and include the appropriate meshes for both visualization and collision. This streamlines the integration of Bota FT sensors into your robot model.
The sensor XACROS must receive the following parameter:
Parameter |
Description |
|---|---|
|
Bota FT sensor link name. It will be used as prefix for the link and joint names the xacro creates. |
The frames that all the XACROs create are shown in the figure below.
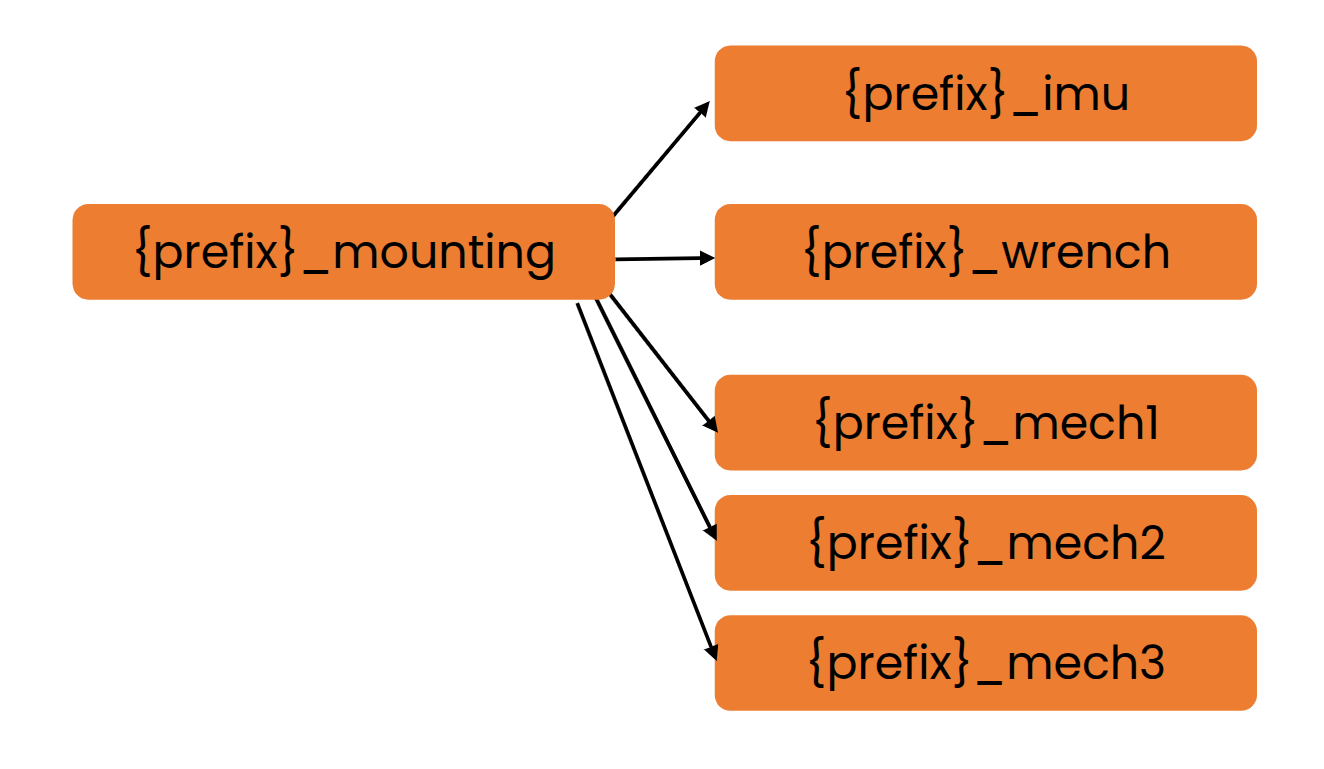
Frames (links) created by Bota FT Sensor XACROs.
This frames are corresponding to the following parts of the sensor:
Frame |
Part |
|---|---|
|
Mounting interface in the back of the sensor. It is the parent for allthe other frames in the sensor. It should be the child for the joint that attaches the sensor to the robot. |
|
Front interface of the sensor, where the measured wrench is referenced and expressed. |
|
[ONLY IF AVAILABLE] Mechanical interfaces on the side of the sensor body. |
A RVIZ visualization of the robot description generated with the XACROs is shown below:
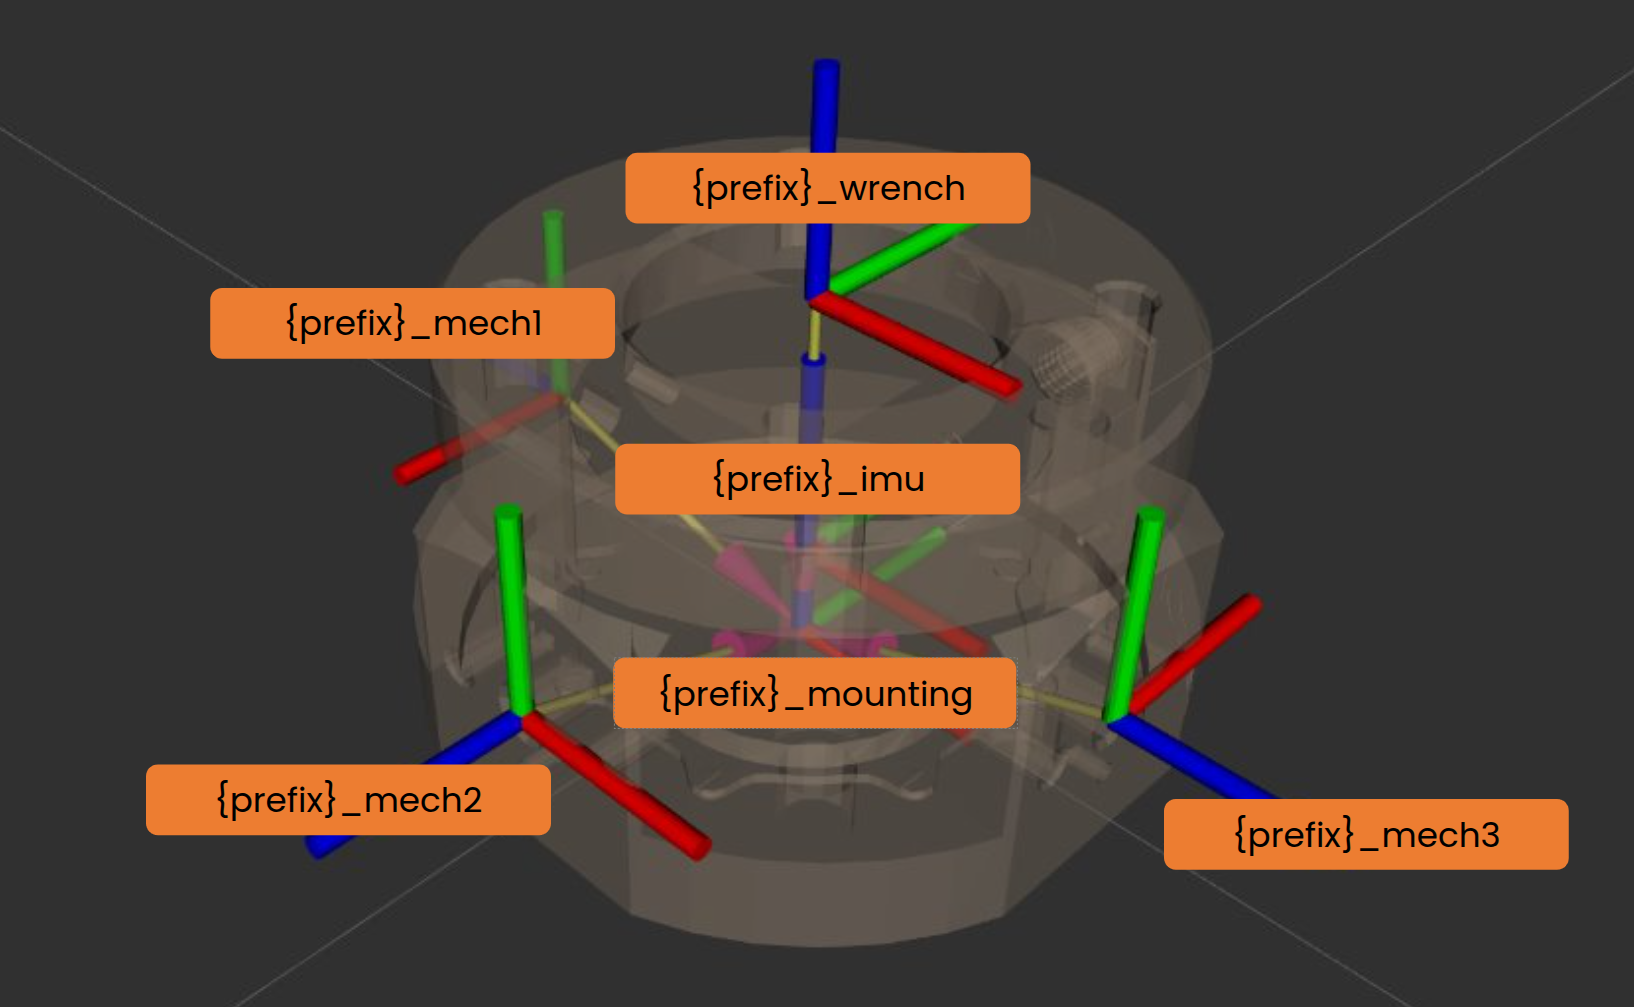
RVIZ visualization.
Supported XACROs
Gen 0
Commercial name |
Macro Name |
IMU link |
|---|---|---|
SensONE Serial |
BFT_SENS_SER_M8 |
No |
SensONE EtherCAT |
BFT_SENS_ECAT_M8 |
Yes |
Rokubi Serial |
BFT_ROKS_SER_M8 |
No |
Rokubi EtherCAT |
BFT_ROKS_ECAT_M8 |
Yes |
Medusa Serial |
BFT_MEDS_SER_M8 |
No |
Medusa EtherCAT |
BFT_MEDS_ECAT_M8 |
Yes |
MiniONE Pro Serial |
BFT_MIPS_SER_M8 |
No |
MiniONE Pro EtherCAT |
BFT_MIPS_ECAT_M8 |
Yes |
LaxONE Serial |
BFT_LAXS_SER_M8 |
No |
LaxONE EtherCAT |
BFT_LAXS_ECAT_M8 |
Yes |
MegaONE Serial |
BFT_MEGS_SER_M8 |
No |
MegaONE EtherCAT |
BFT_MEGS_ECAT_M8 |
Yes |
Gen A
>> ONE-Series
Commercial name |
Product Name -> Macros Name |
|---|---|
SensONE |
BFT_DENS_CAT2_B4, BFT_DENS_IND2_B4, BFT_SENS_CAT2_B4, BFT_SENS_IND2_B4 |
Rokubi |
BFT_MEDS_CAT2_B4, BFT_MEDS_IND2_B4, BFT_ROKS_CAT2_B4, BFT_ROKS_IND2_B4 |
MiniONE Pro |
BFT_MIPS_CAT1_CG, BFT_MIPS_ENET_CG |
MiniONE |
BFT_MN2S_SER_UB, BFT_MN2S_SER_ML |
LaxONE |
BFT_LAXS_CAT2_B4, BFT_LAXS_IND2_B4 |
MegaONE |
BFT_MEGS_CAT2_B4, BFT_MEGS_IND2_B4, BFT_NEGS_CAT2_B4, BFT_NEGS_IND2_B4 |
SensONE T80 |
BFT_MENS_CAT2_B4, BFT_MENS_IND2_B4 |
PixONE T25 |
BFT_SH1_CAT2_BD, BFT_SH1_IND_BD |
PixONE T60 |
BFT_MH1_MLP_BD |
Kinova Gen3 Sensor |
BFT_KG32_IND3_SW |
>> X-Series
Commercial name |
Product Name -> Macros Name |
|---|---|
TactX |
BFT_MN3S_USB_ML |
MimX |
BFT_MM1X_USB_ML |
PhisX |
BFT_PH1X_USB_ML |
Variants
Ready to Get Started?
Select the ROS2 driver variant that best fits your application needs.